Duality Between Incremental Nonlinear Dynamic Inversion and Quasi-Linear Parameter-Varying Control
Abstract
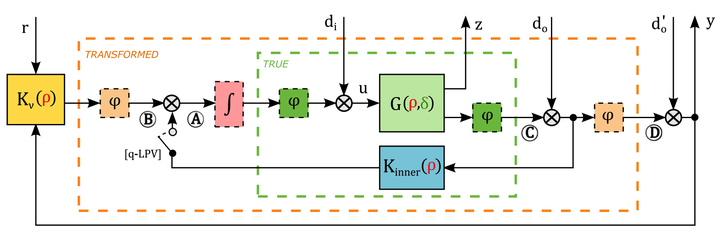
This paper investigates the duality between incremental nonlinear dynamic inversion (INDI) and quasi-linear parameter-varying (q-LPV) control within a transformation-based framework for robust nonlinear control. It develops q-LPV representations of closed-loop systems governed by INDI and nonlinear dynamic inversion (NDI), considering different inversion strategies. These representations enable LPV-based robustness analysis and controller synthesis, including cases involving singular perturbations that prevent perfect inversion. The framework is demonstrated using a nonlinear aeroservoelastic system. INDI-based control designs are developed and evaluated against direct q-LPV controllers constructed through linear fractional transformations.