Abstract
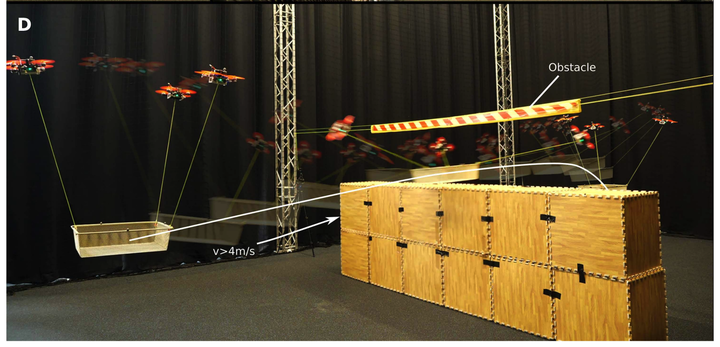
This paper presents a framework for agile cooperative aerial manipulation of cable-suspended loads using multiple quadrotors. Existing multi-quadrotor transportation systems are often limited to low-speed and low-acceleration operations due to the complex dynamic coupling between the vehicles and the suspended load. To overcome these limitations, a trajectory-based framework is developed for online whole-body kinodynamic motion planning, explicitly accounting for coupled dynamics and system constraints. The resulting trajectories are supplied to individual quadrotors in a receding-horizon manner and tracked using onboard controllers that estimate and compensate for cable tensions. Experimental results demonstrate accelerations at least eight times higher than those achieved by existing methods, enabling agile maneuvers including high-speed navigation through narrow passages. The framework also demonstrates robustness against load uncertainties and wind disturbances without requiring additional sensors on the suspended load.